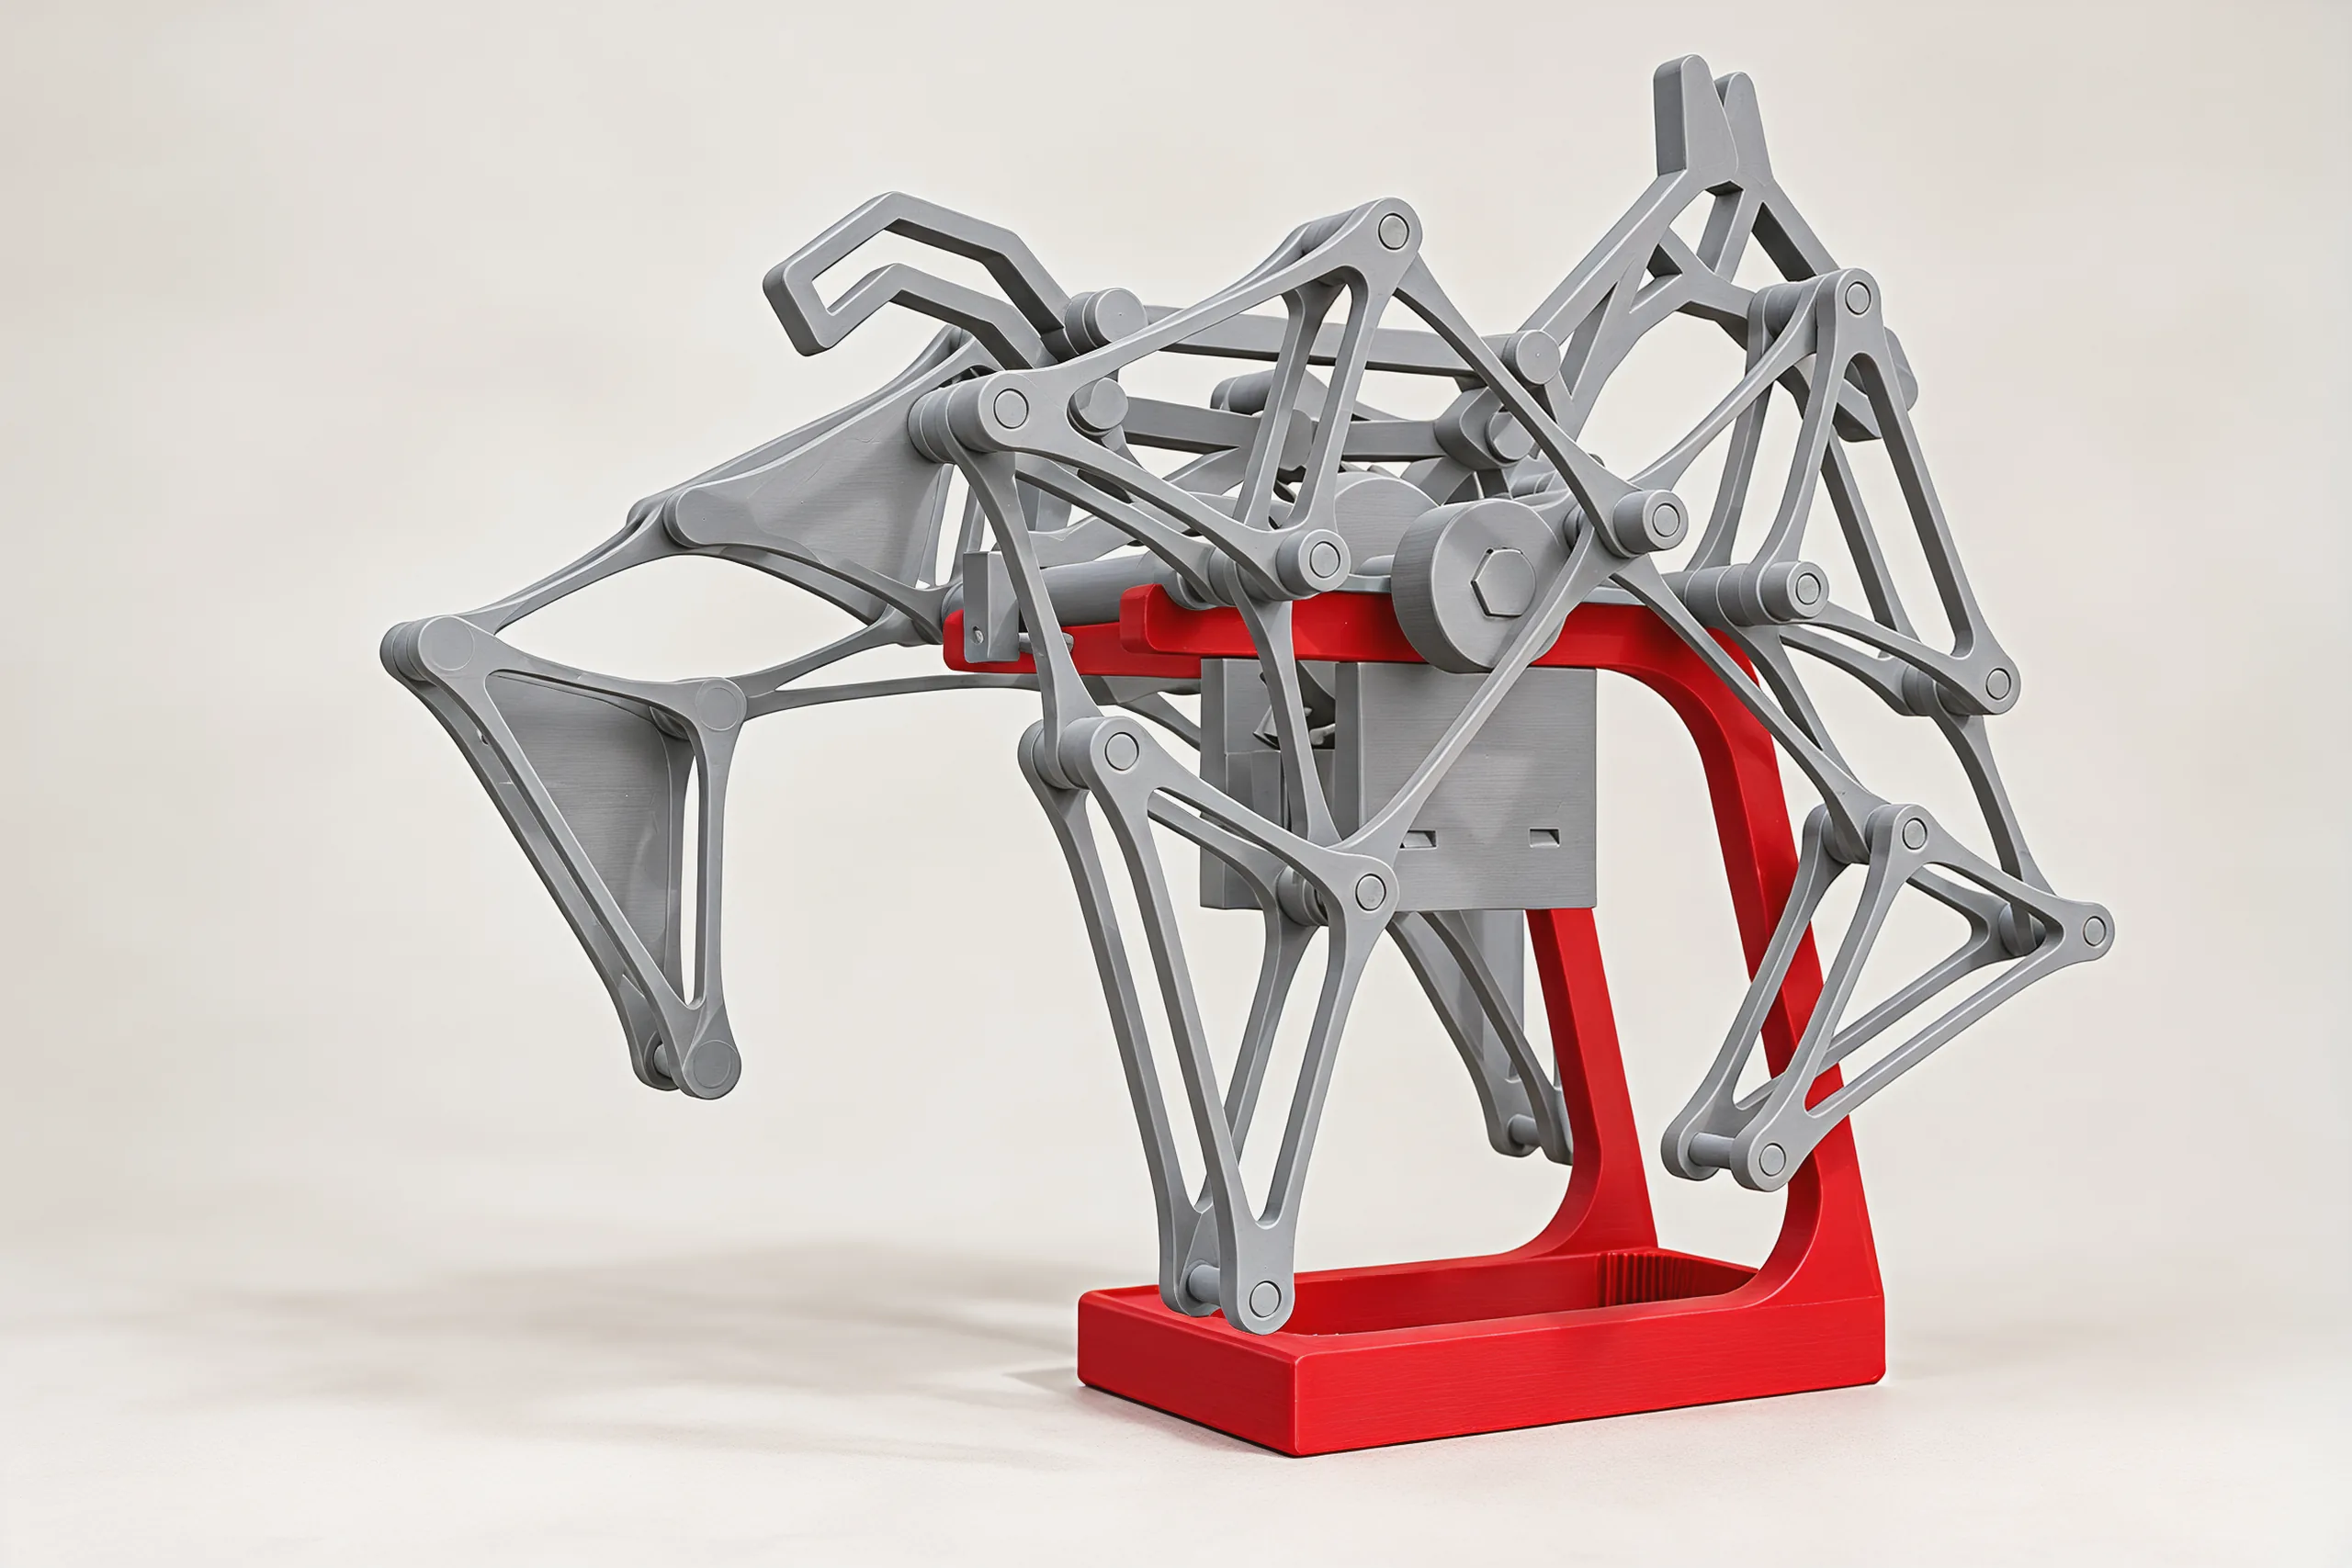
It starts under the body.
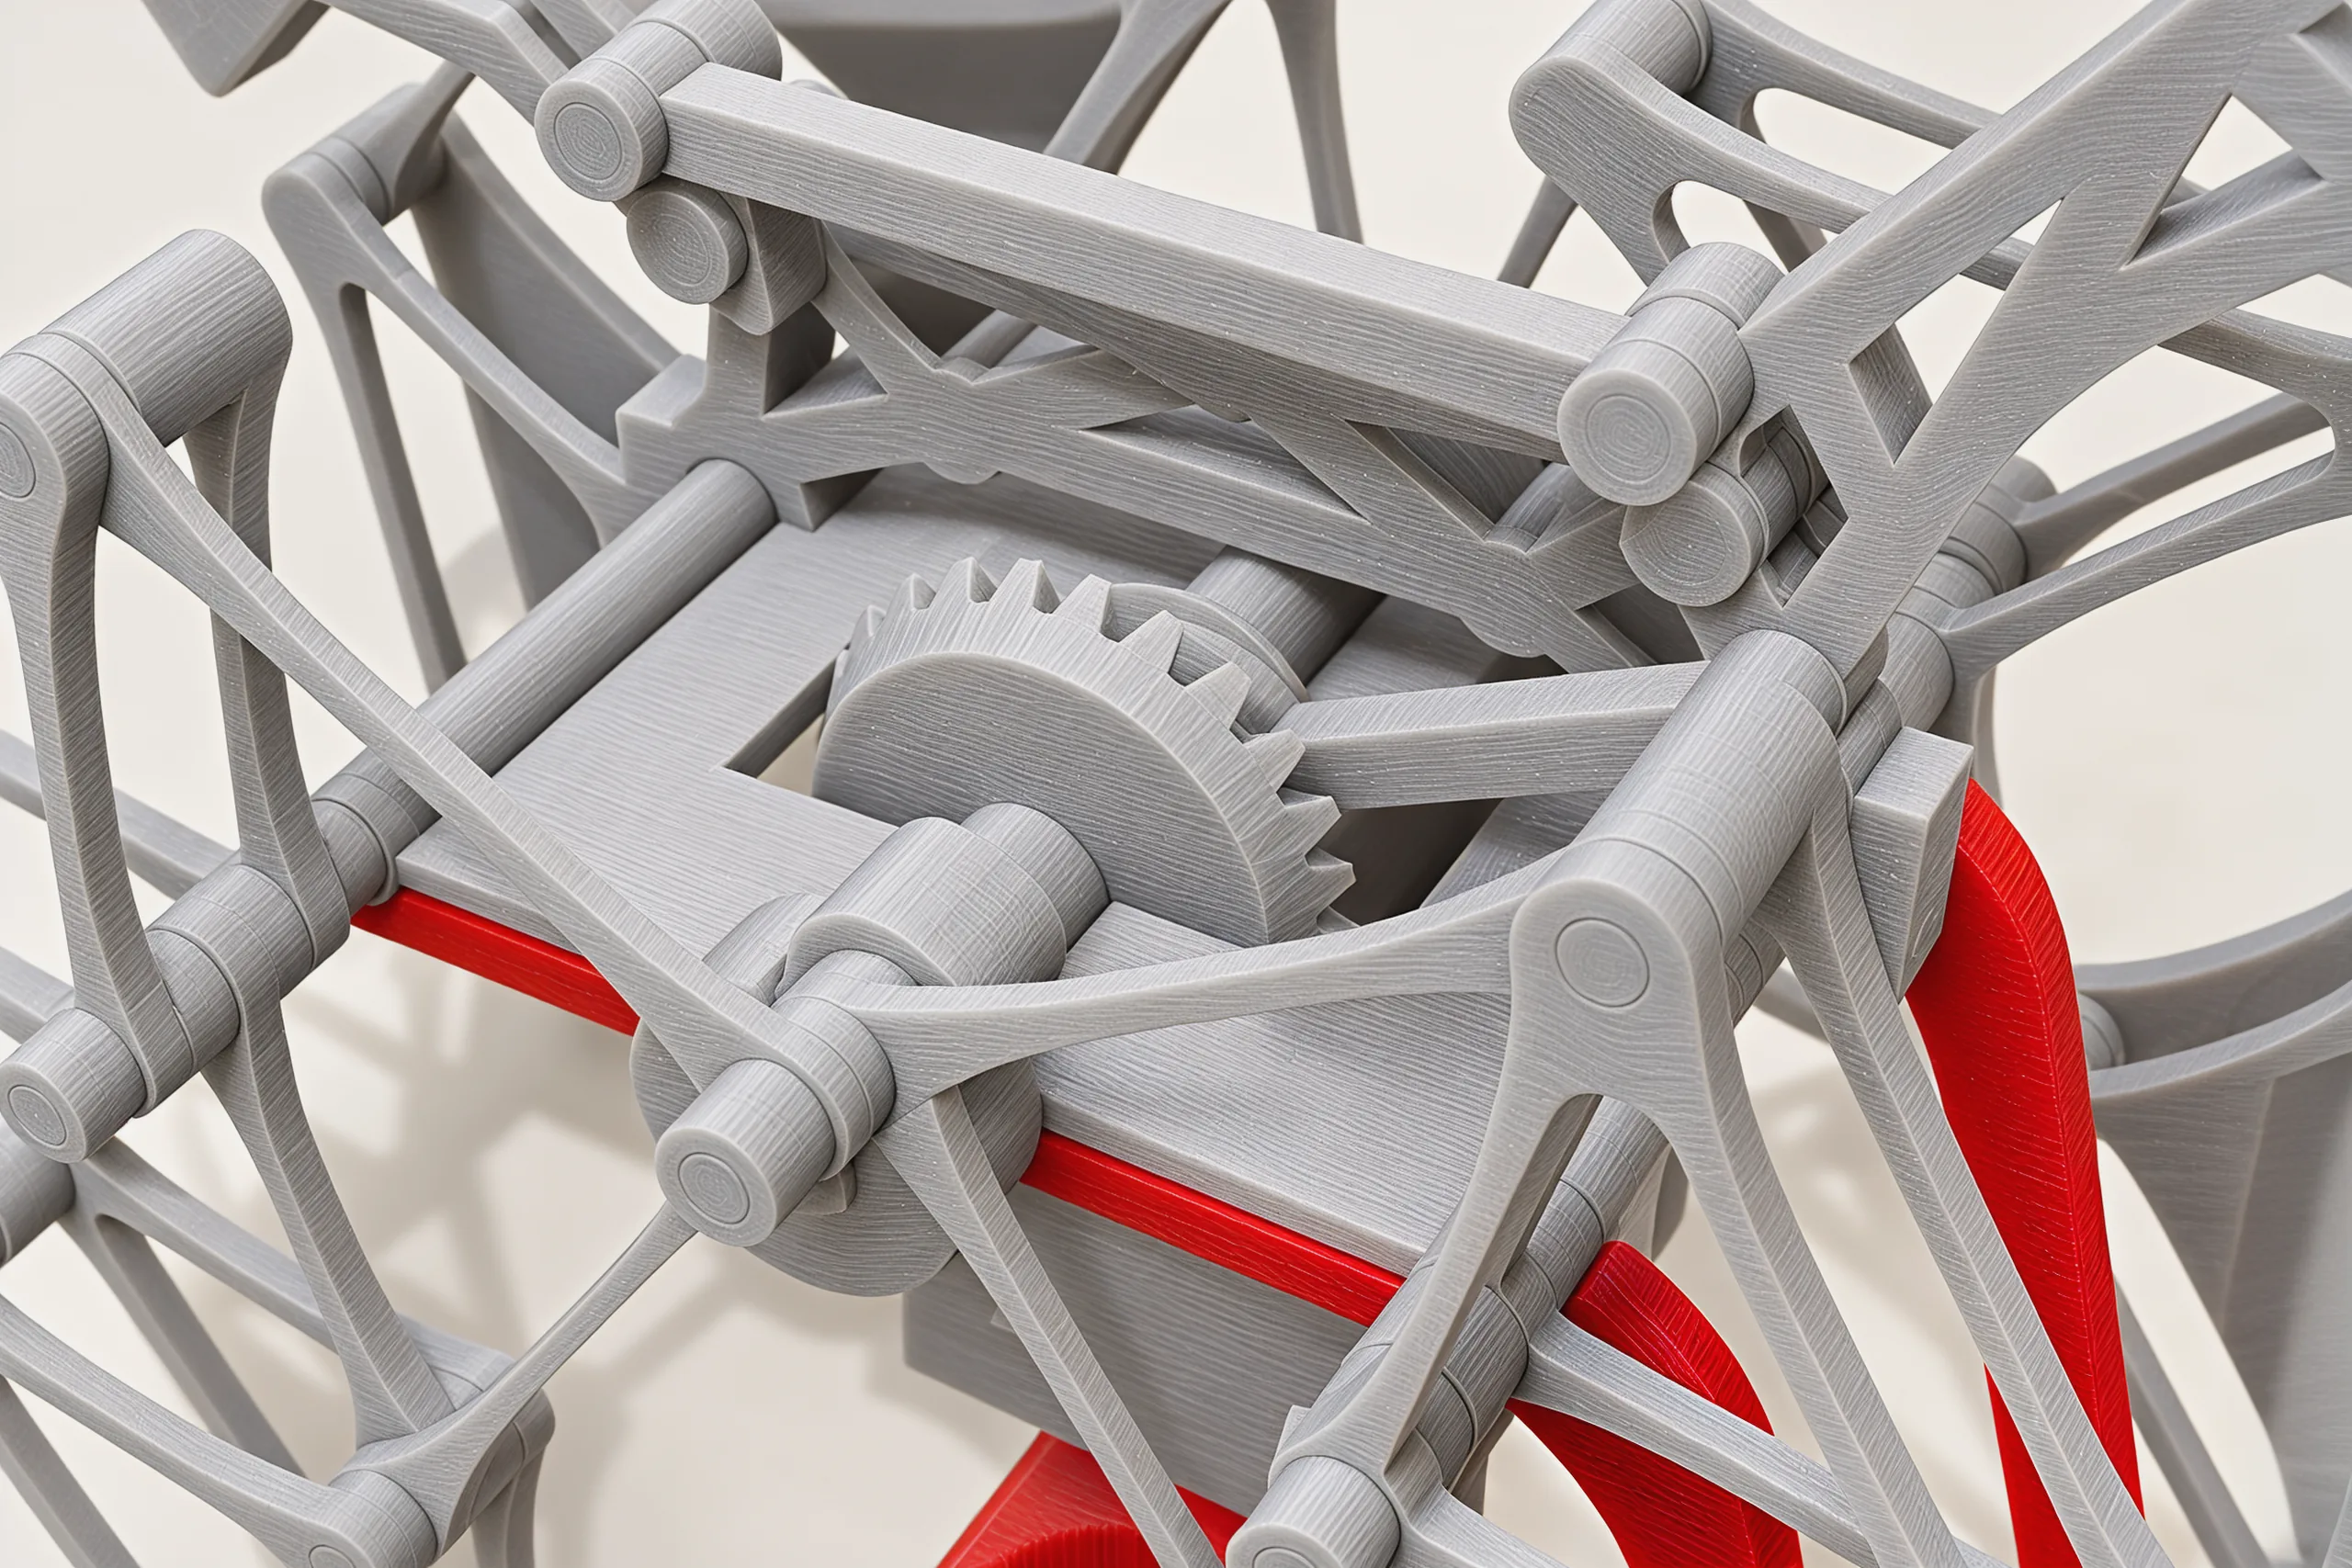
The drive sits here, below the gears. Give the wheel on either side of the horse a turn by hand and every part after it moves with it.
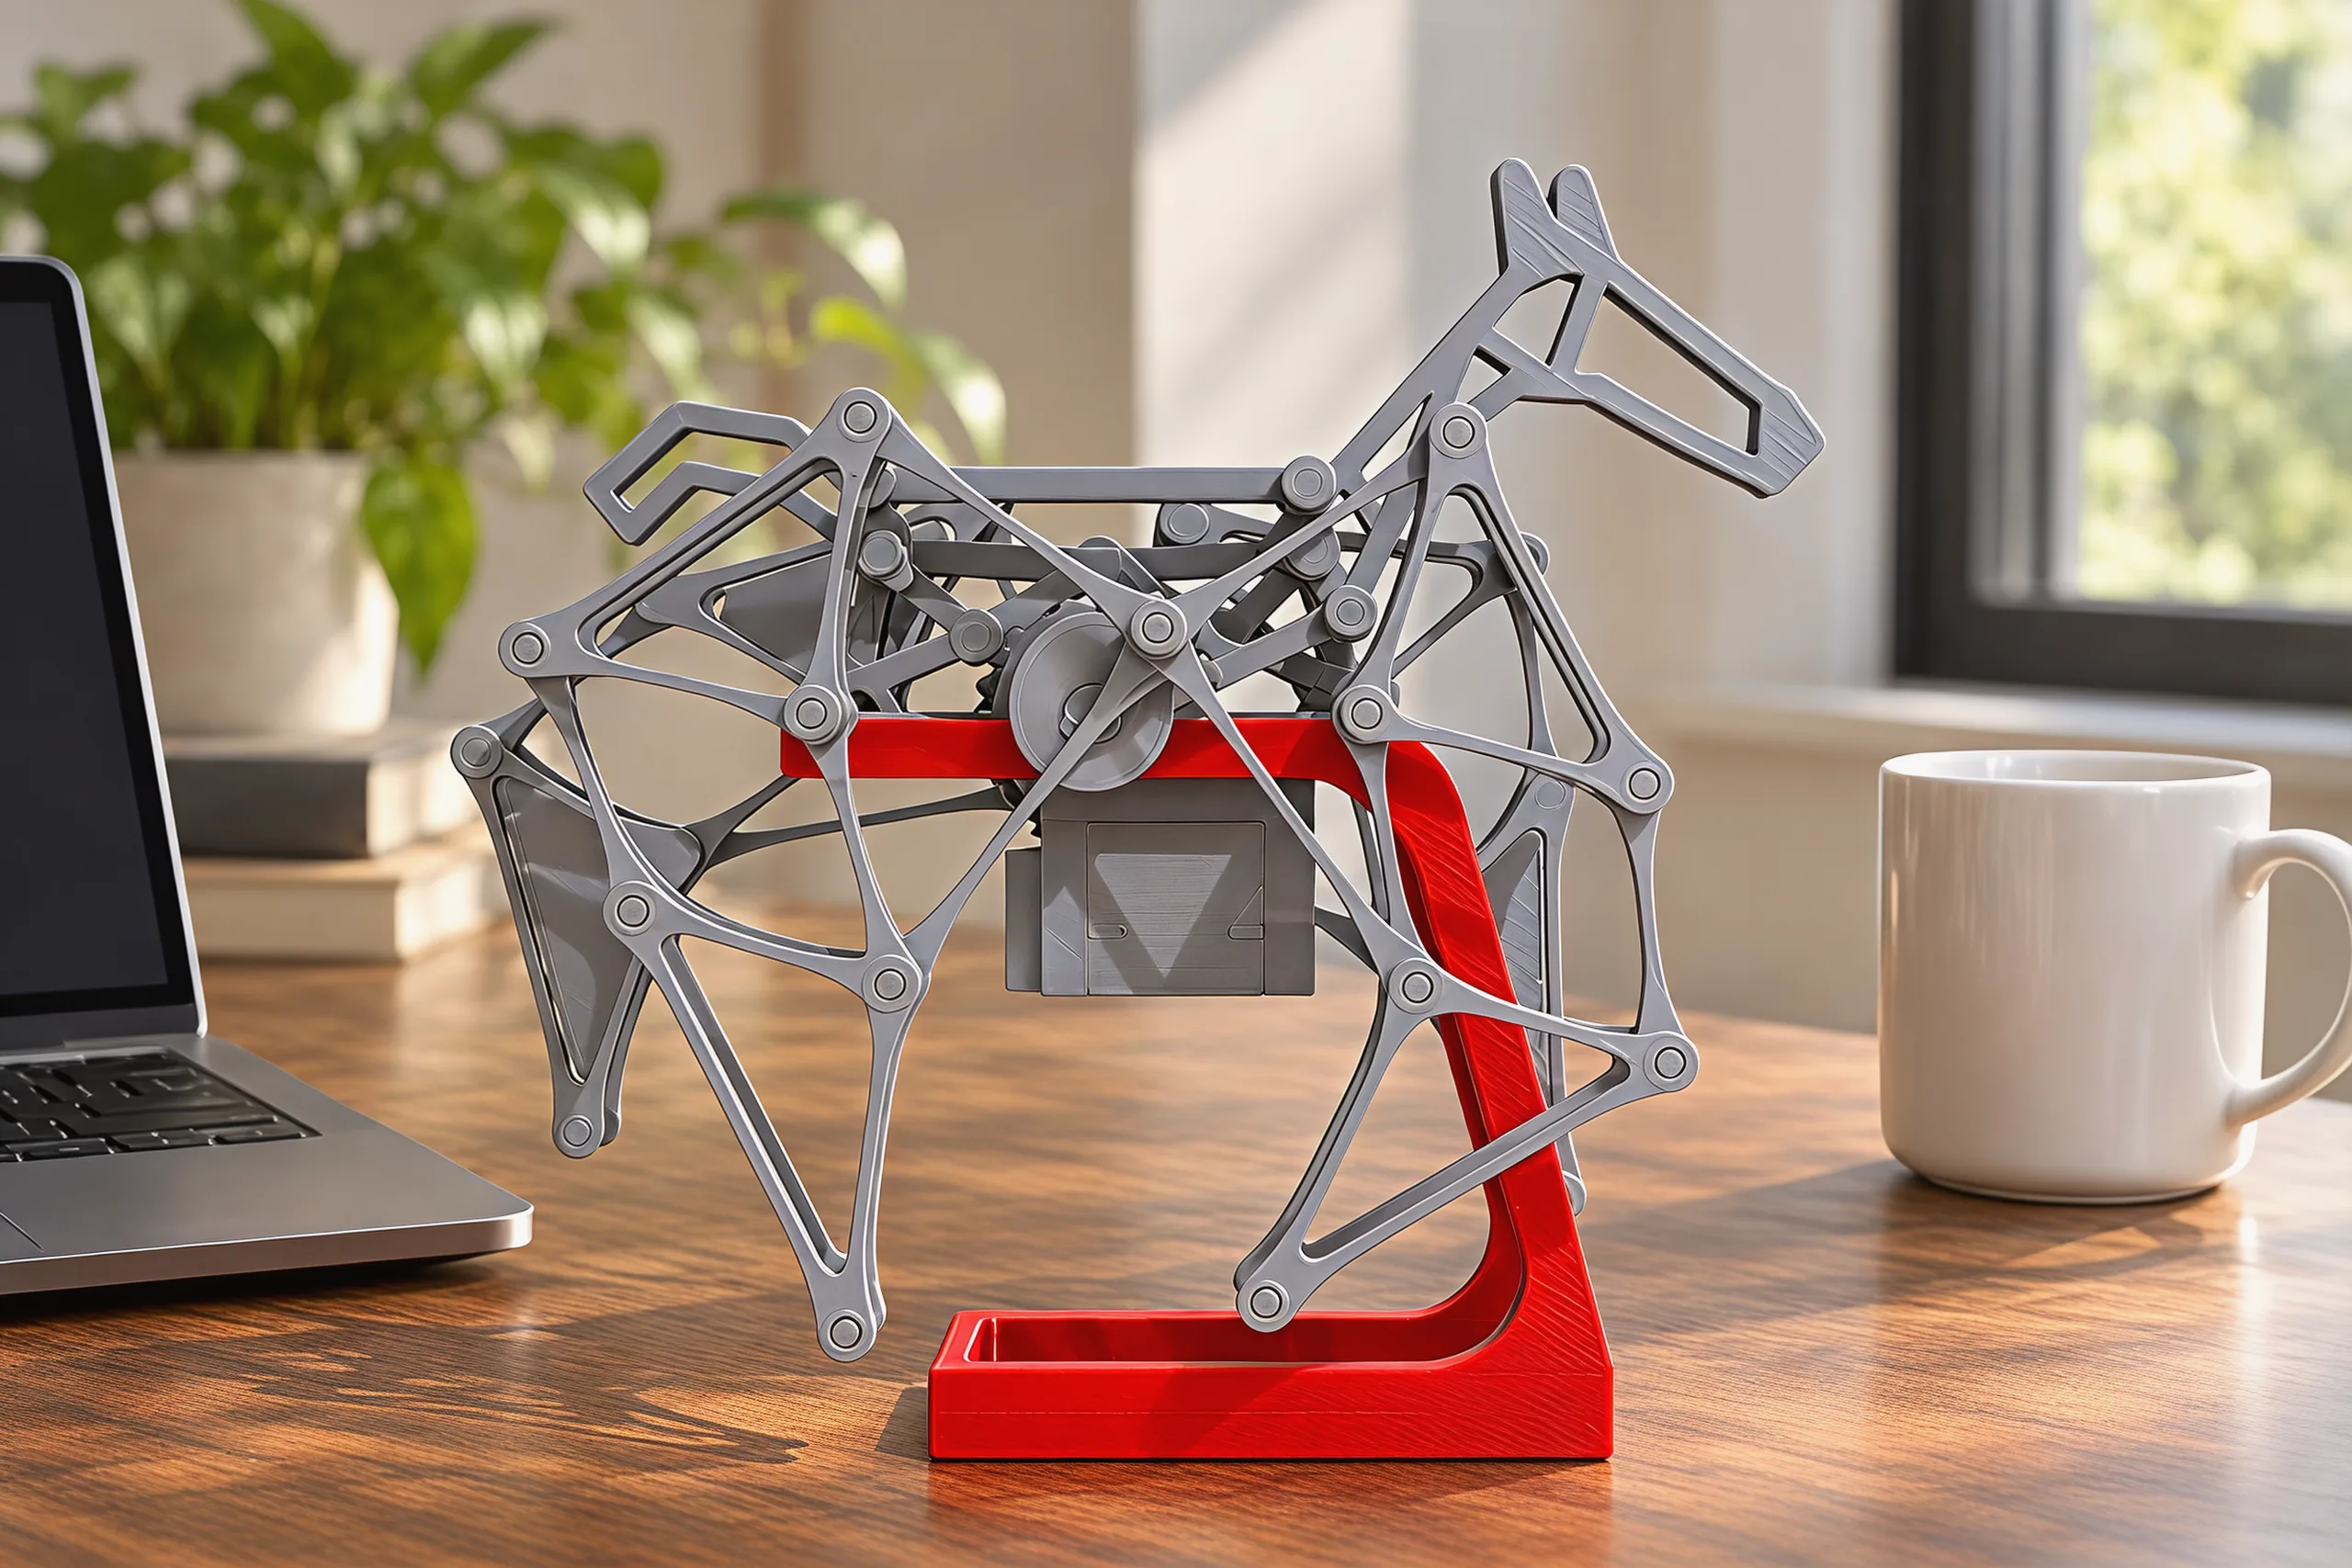
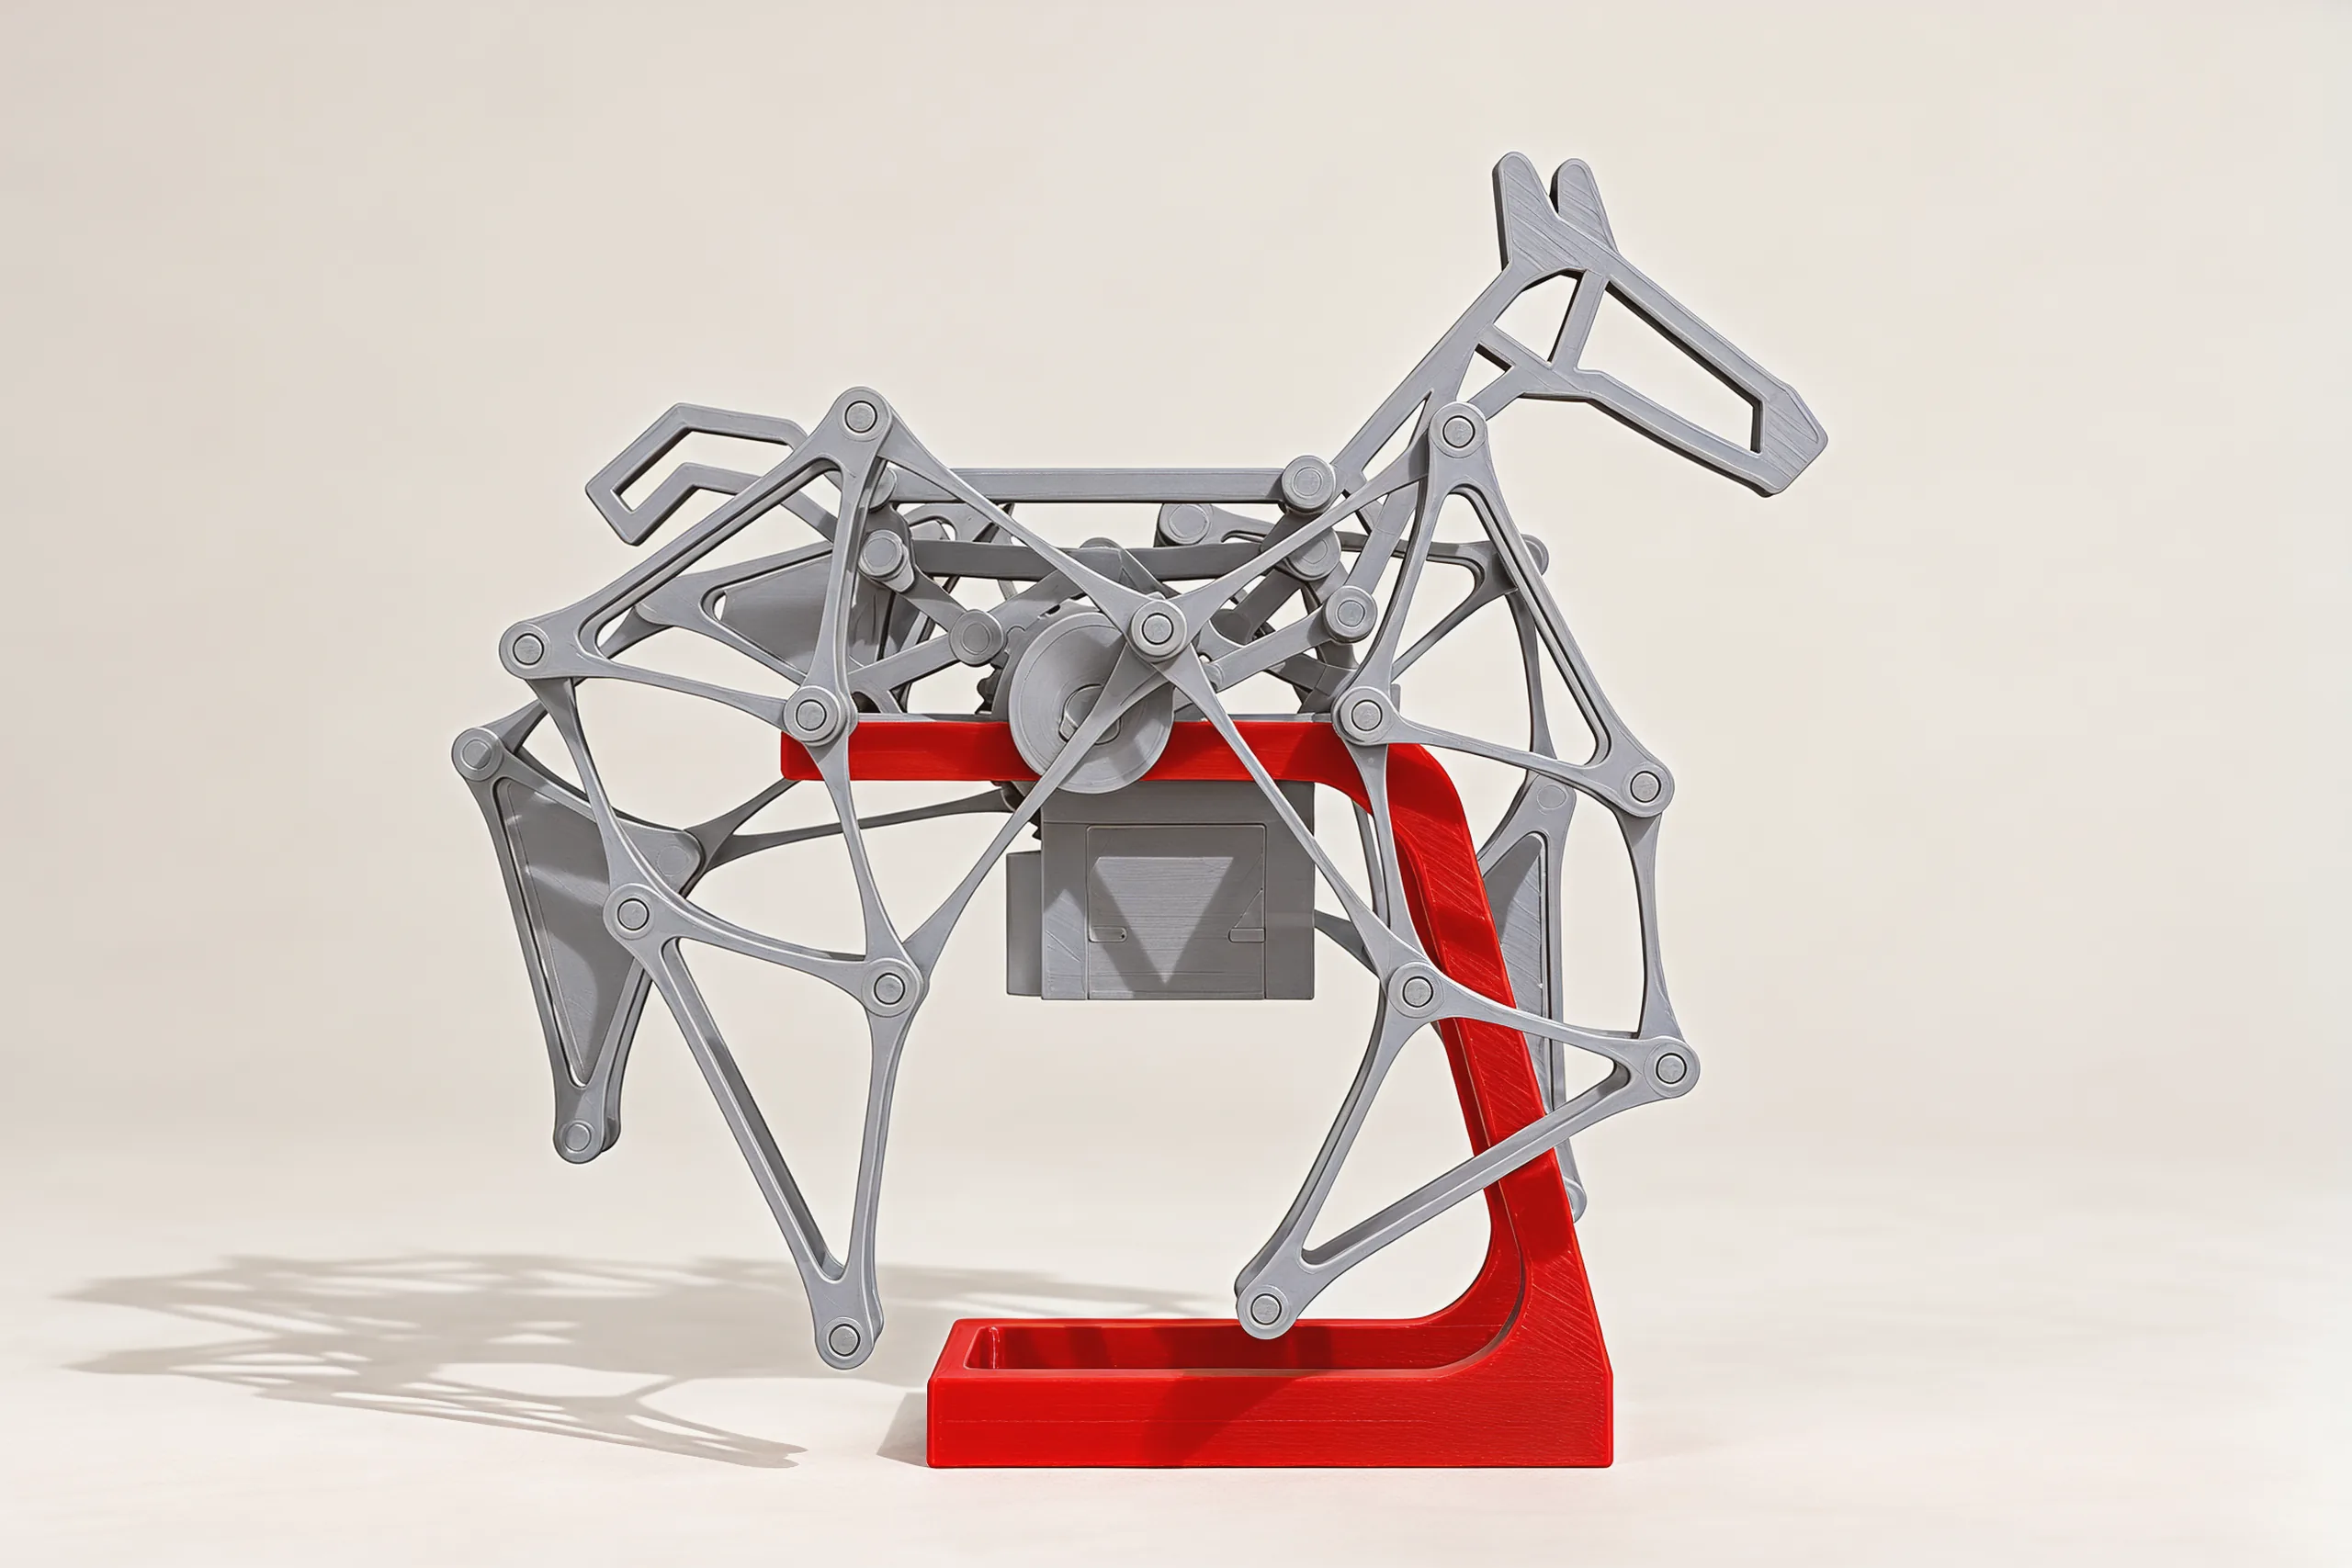
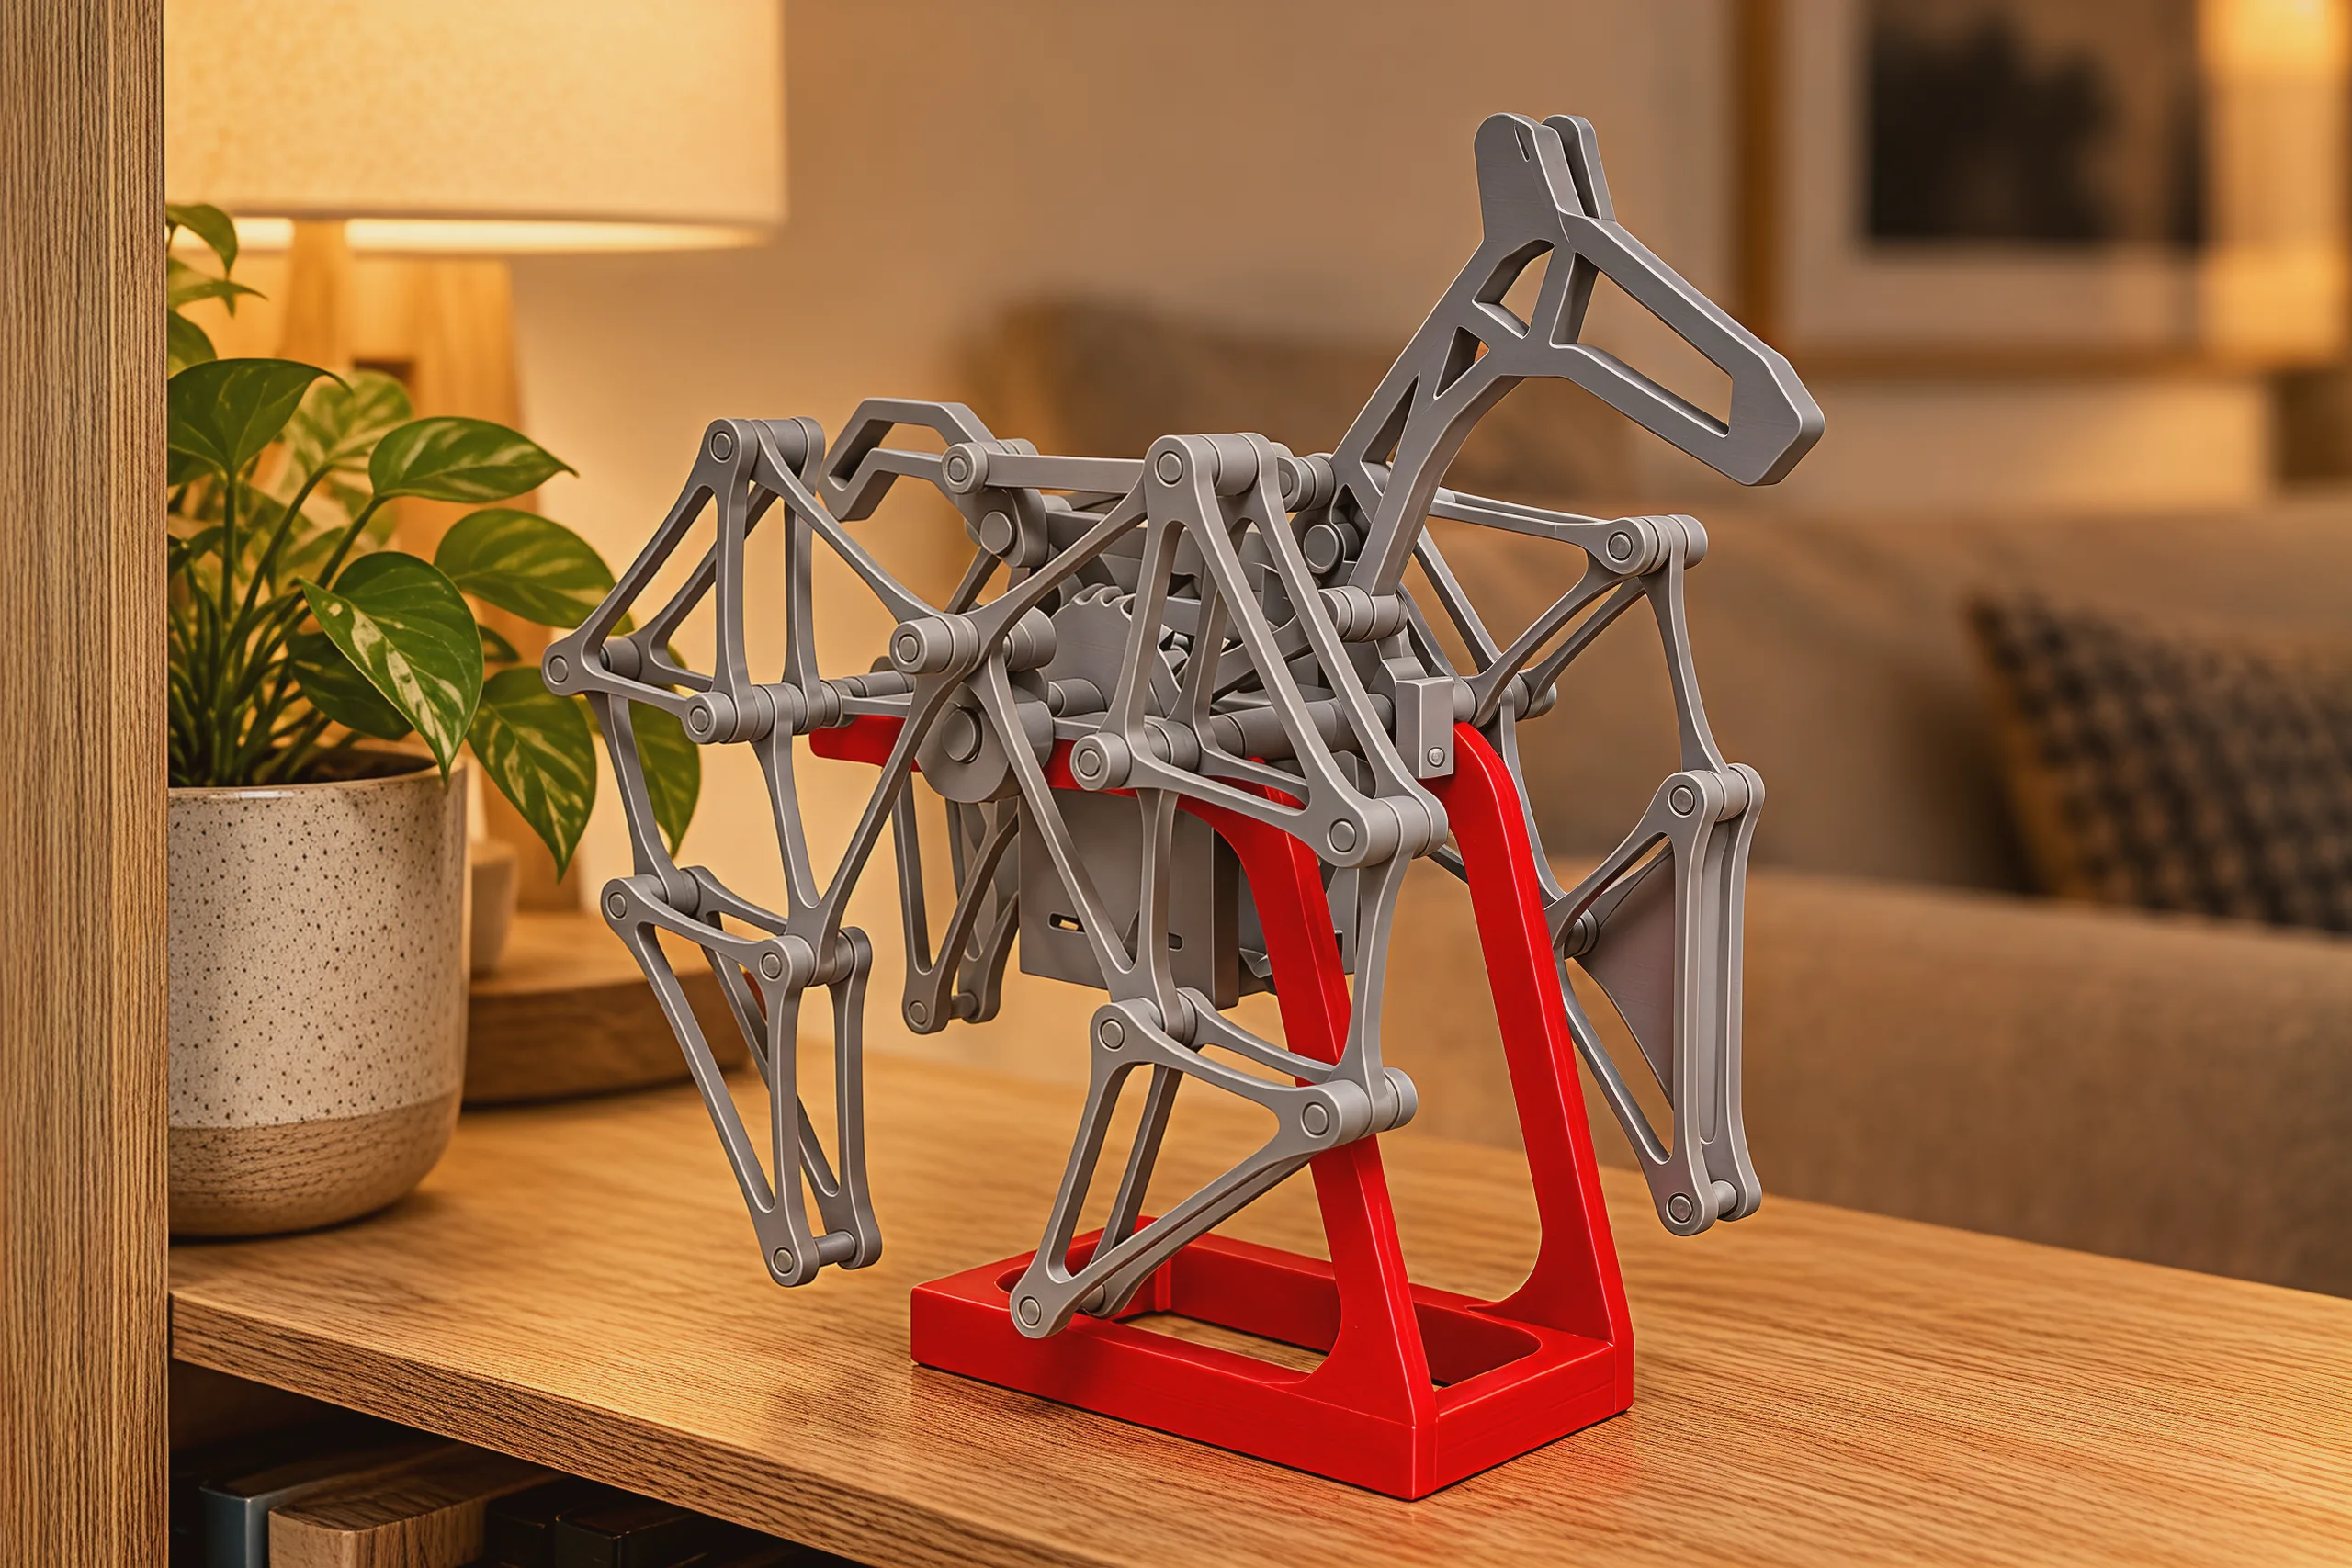
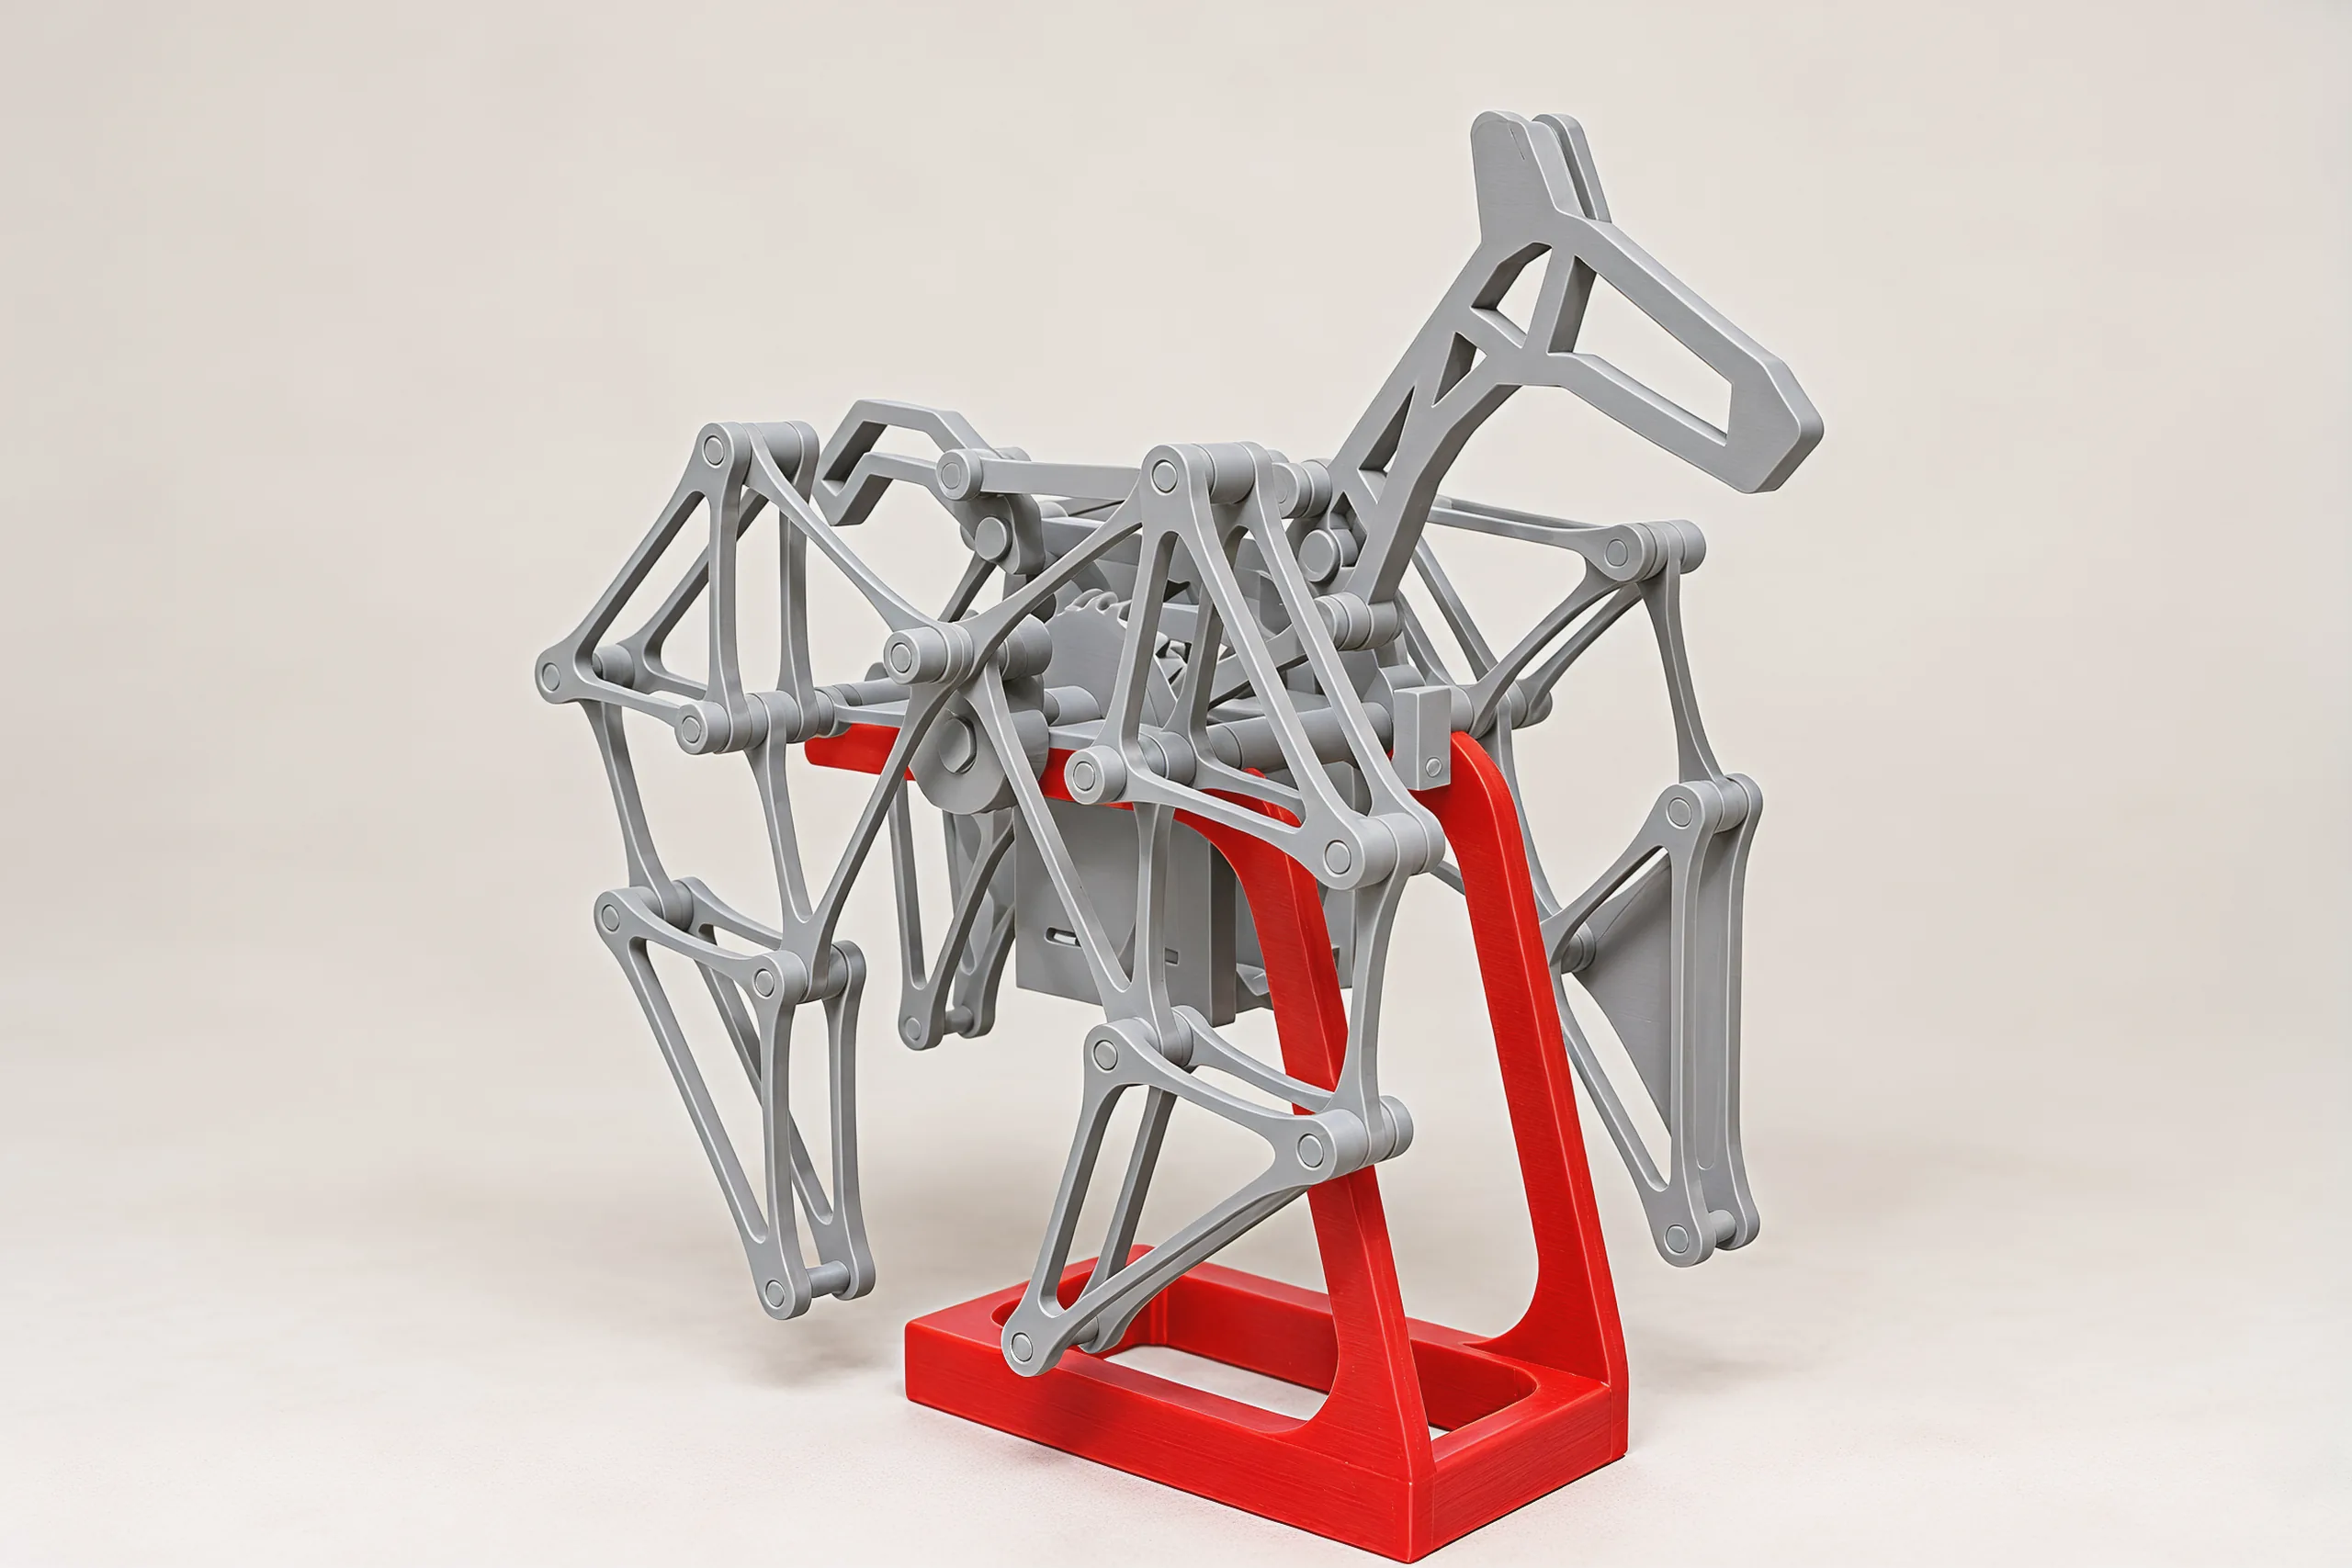
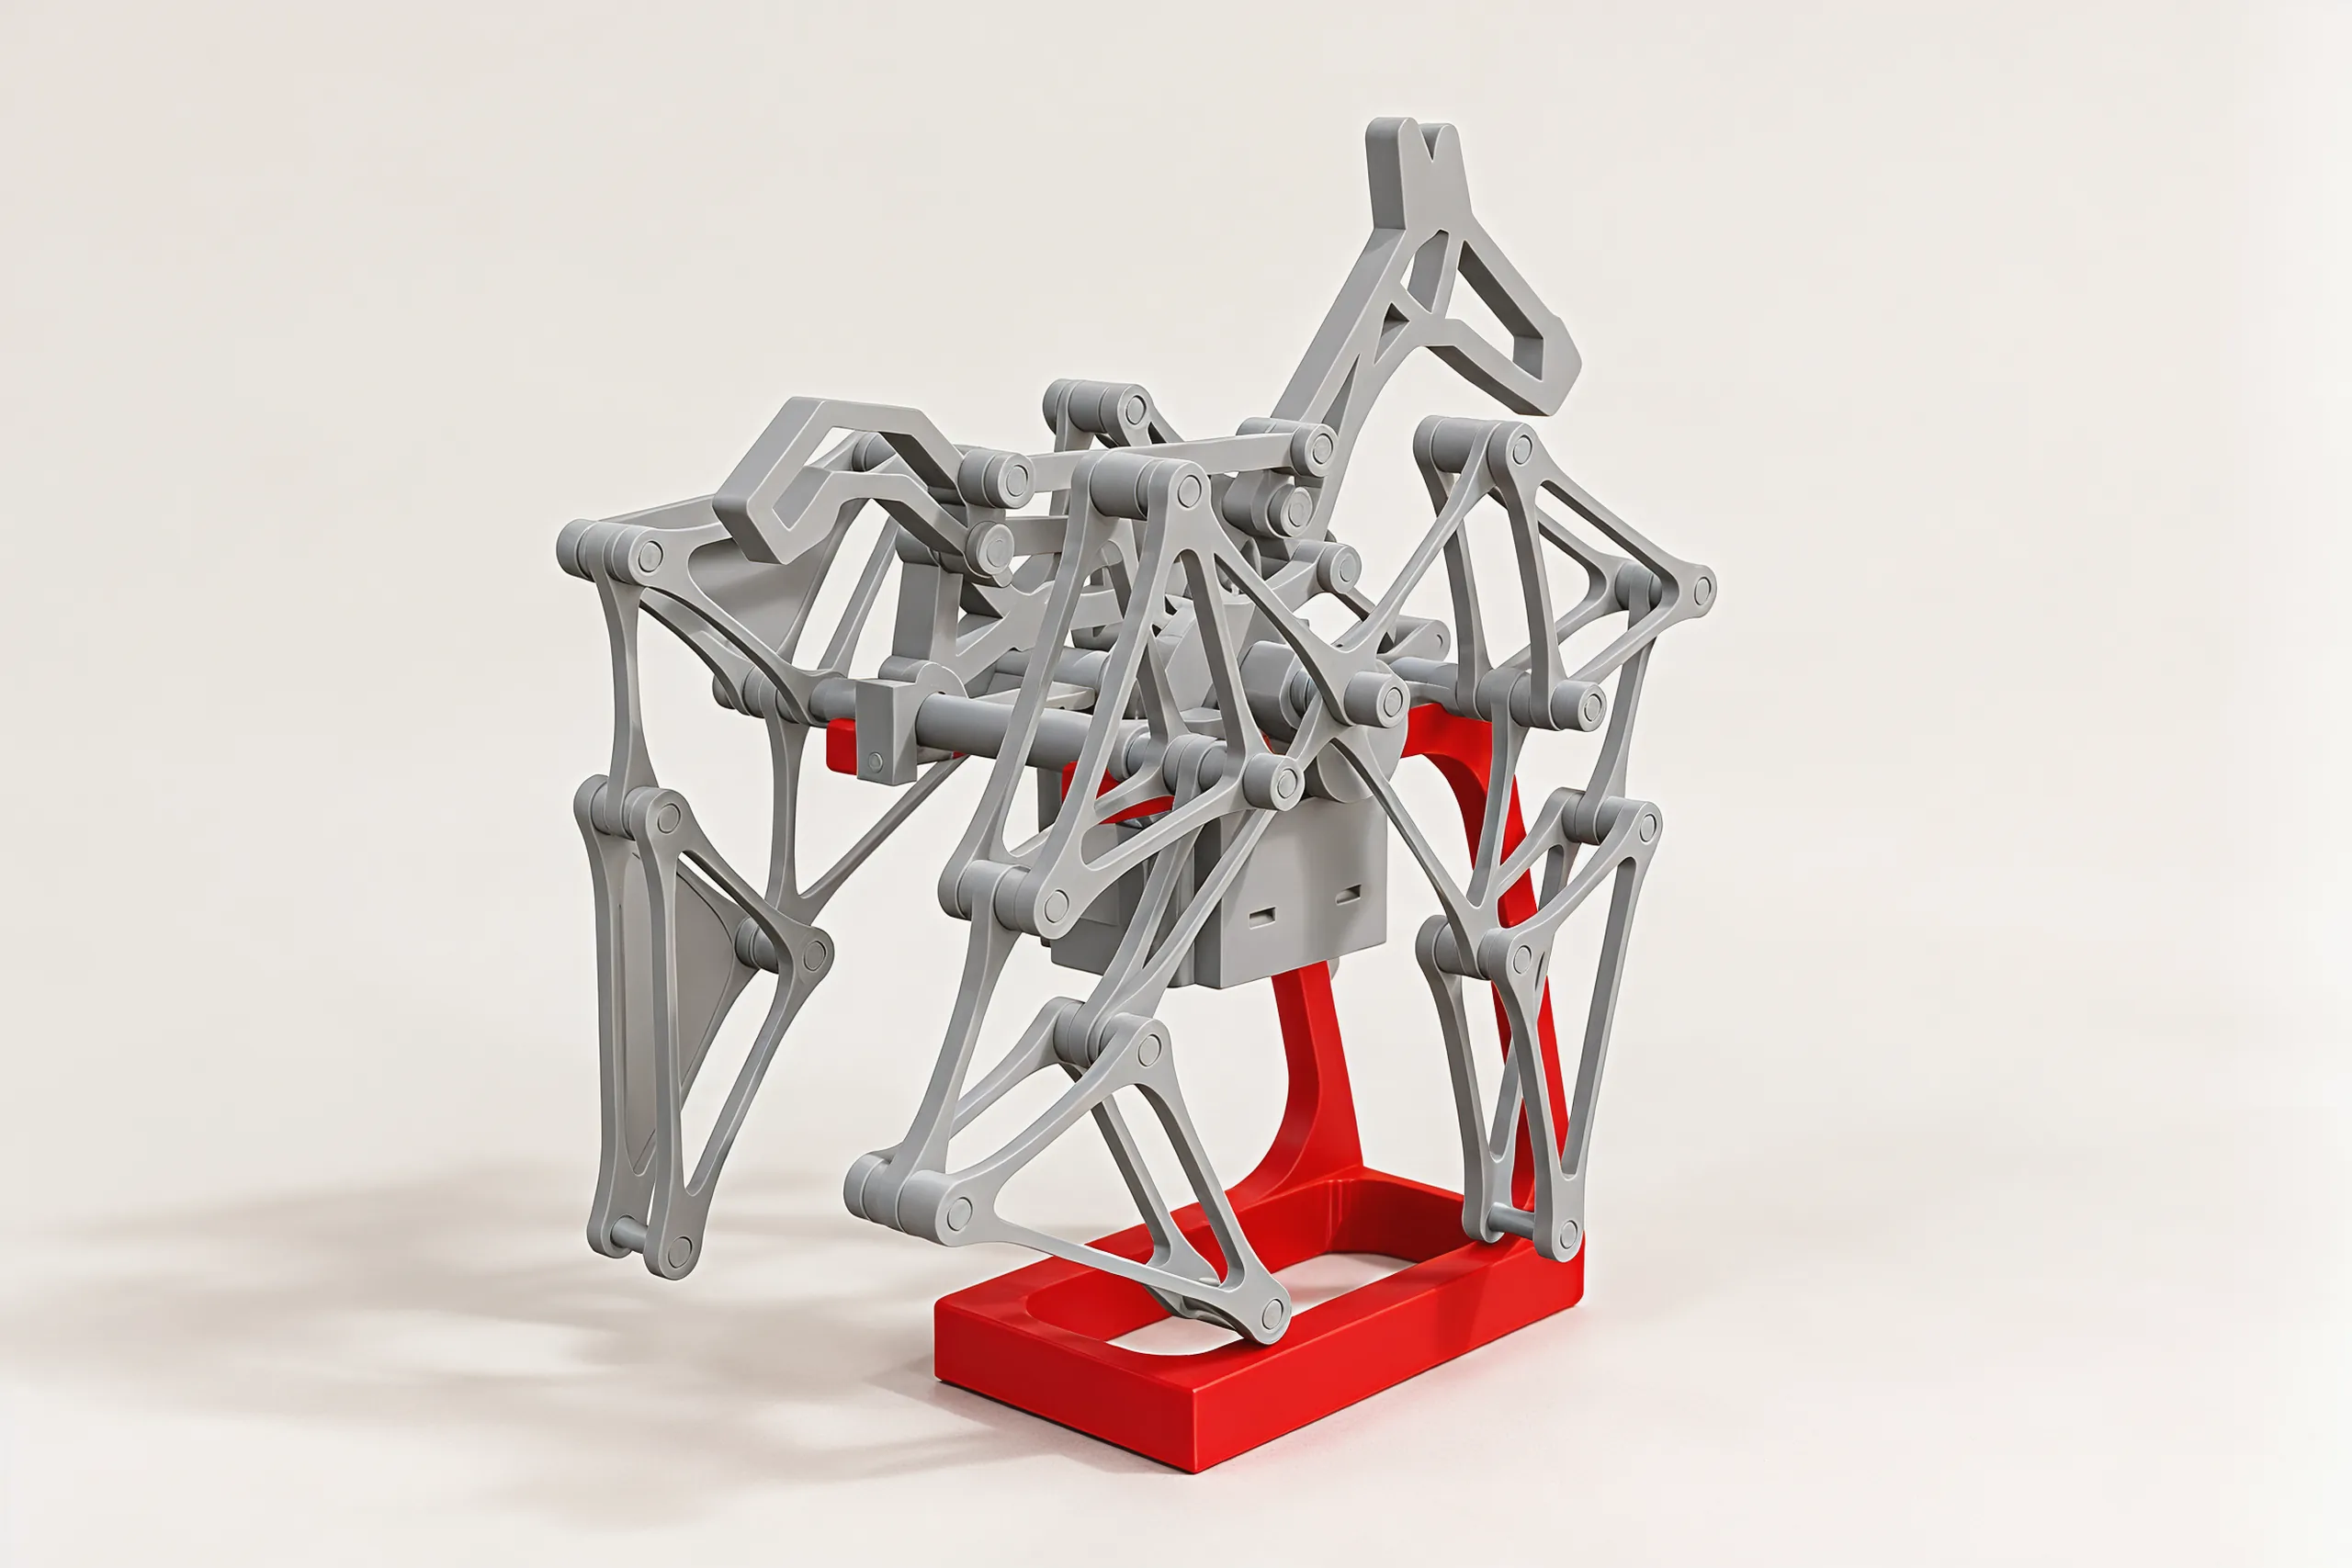
One turning shaft, four Jansen legs, a head that nods and a tail that swings with every step.
The drive sits here, below the gears. Give the wheel on either side of the horse a turn by hand and every part after it moves with it.
A 12-tooth bevel standing on end meshes with a 24-tooth bevel on the crank line: two turns of the small one for every turn of the crank.
The crank line runs across the body to a wheel at each side, each with a pin set off its centre. Each side of the horse hangs its two legs on one pin, so one side lifts while the other pushes.
Every leg is Theo Jansen's linkage, two triangles and four rods. The pin only goes round; the hoof follows the sand line, flat along the bottom for the push and lifted for the return, a step 2.7 in long.
The foreleg and hind leg on a side share one pin and reach in opposite directions; the far side runs half a turn behind. Some hooves always push while the rest swing forward.
A second, smaller wheel on the crank line pushes a rod up into the neck, which rocks through about 21° on its pin at the withers. A bar along the back passes the same rock to the tail.
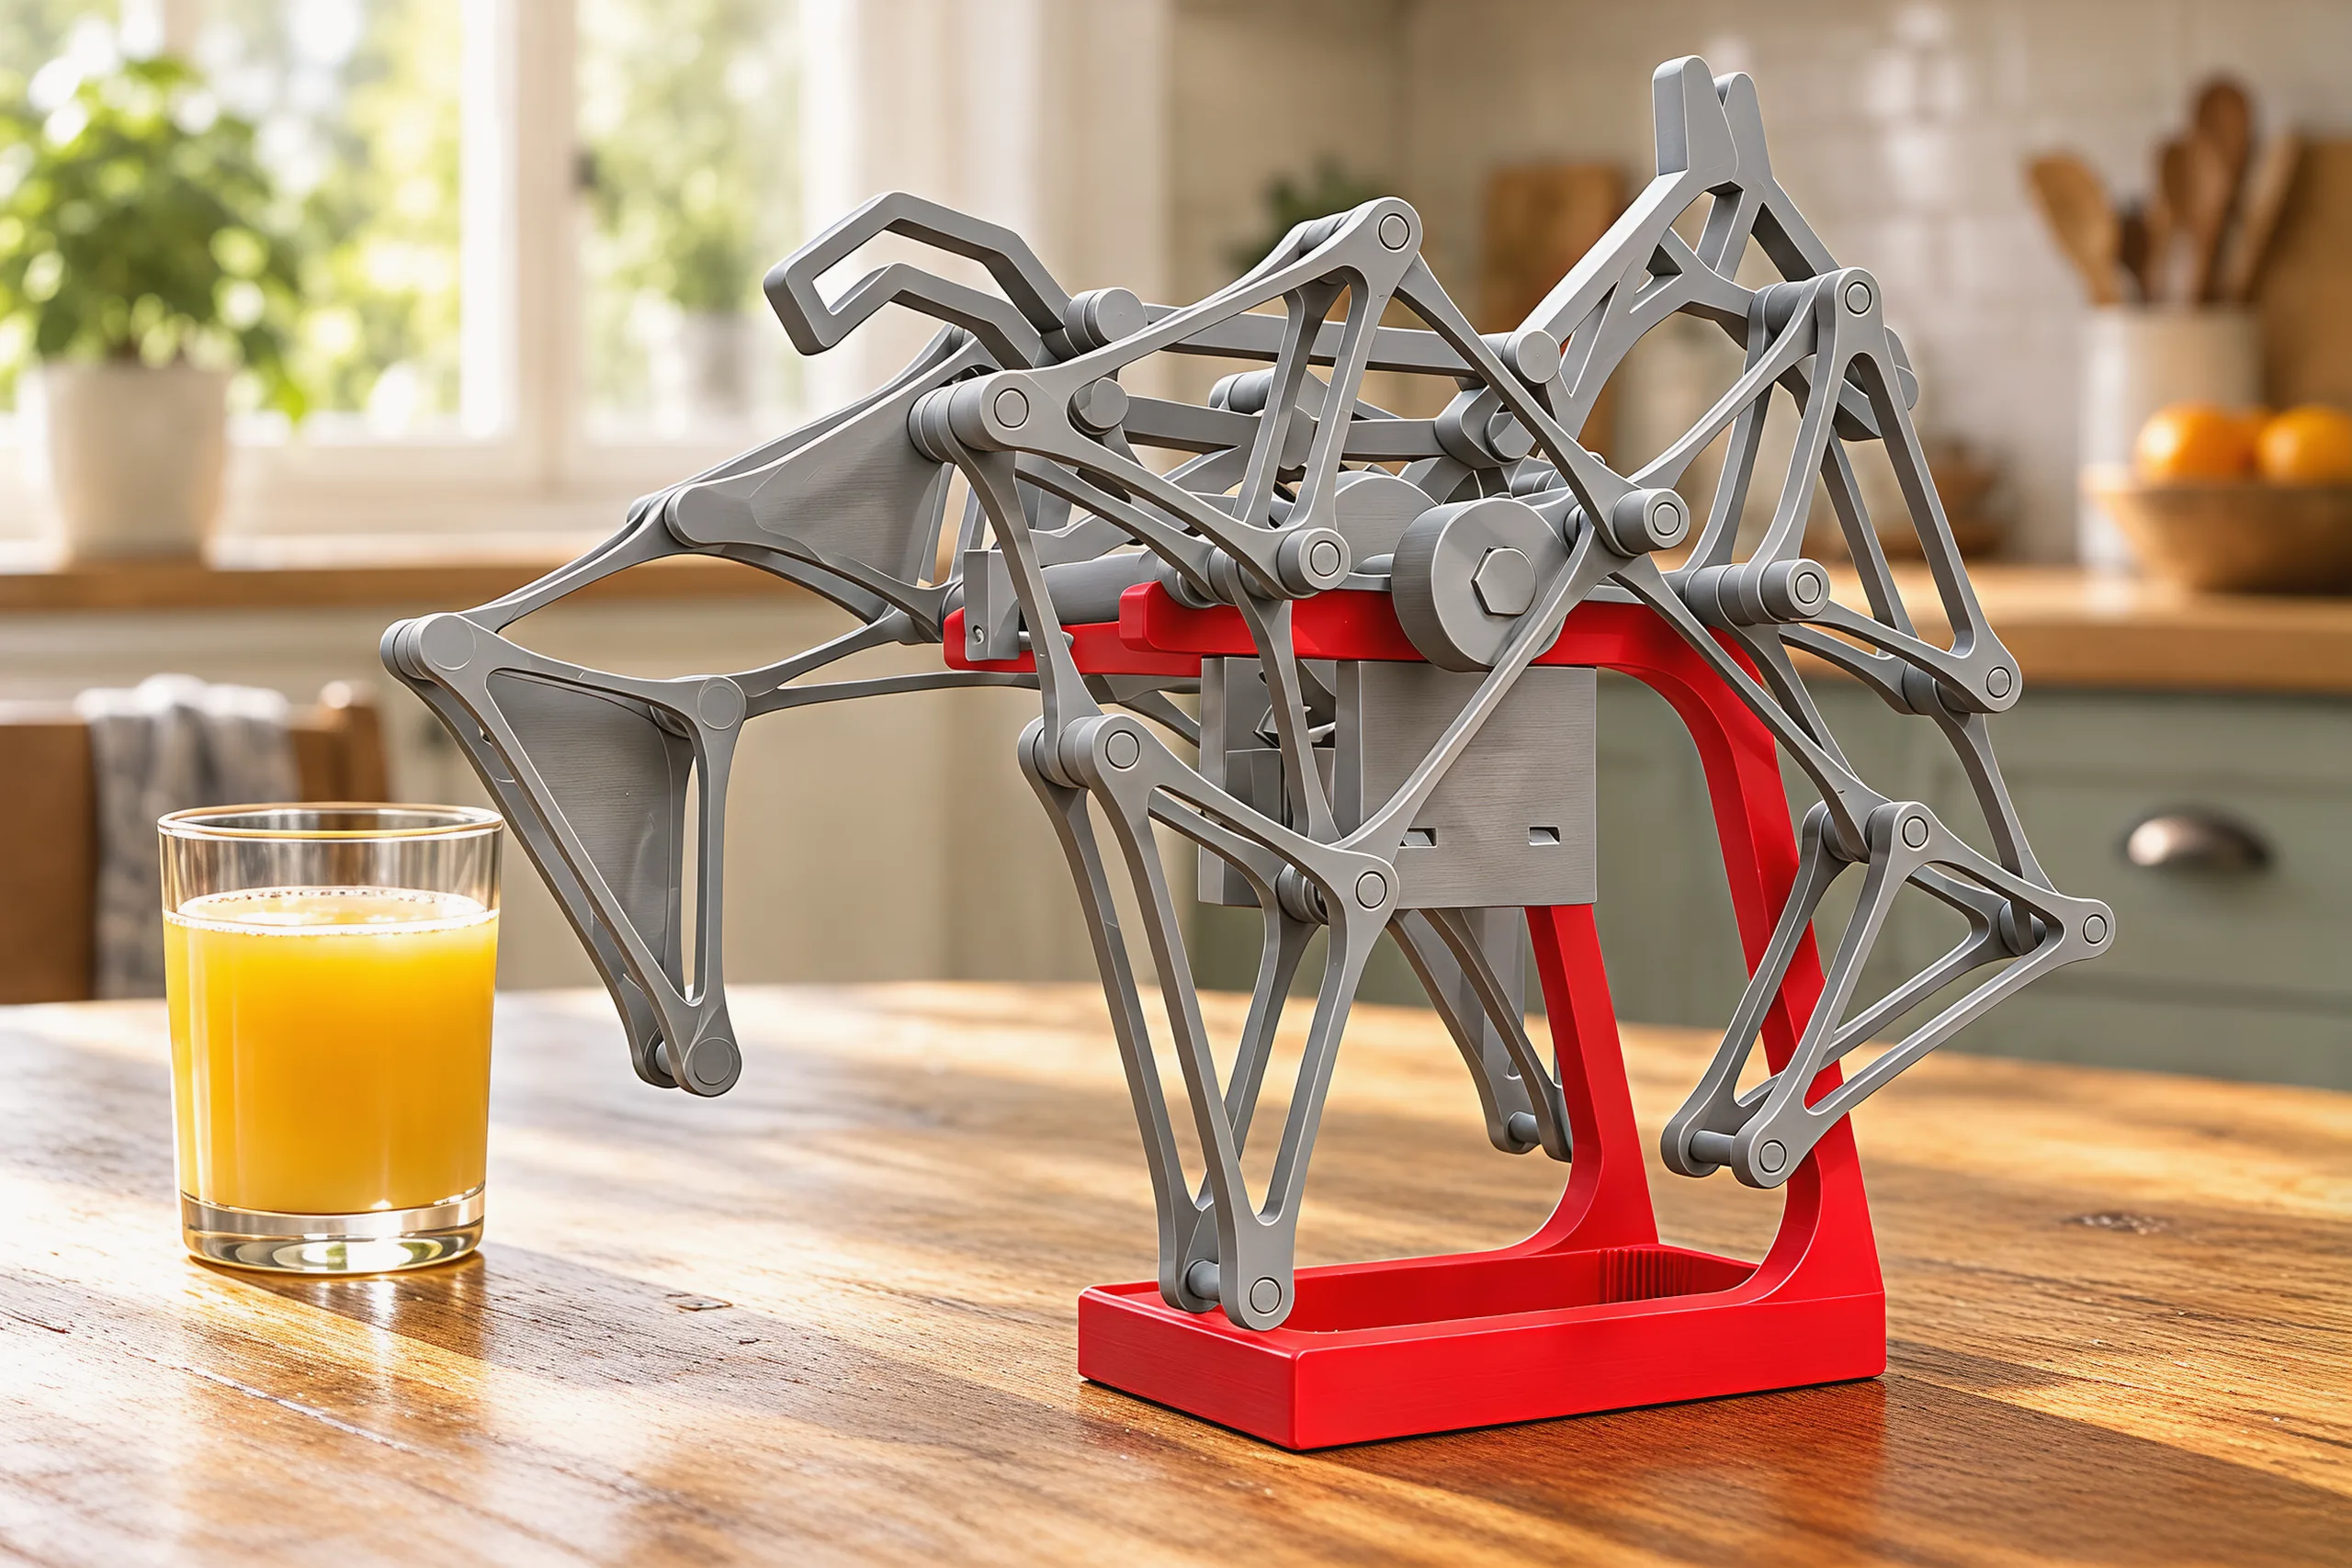
The red stand holds the body up, so the hooves swing 0.7 in clear of the desk. The horse walks on the spot for as long as you keep turning.
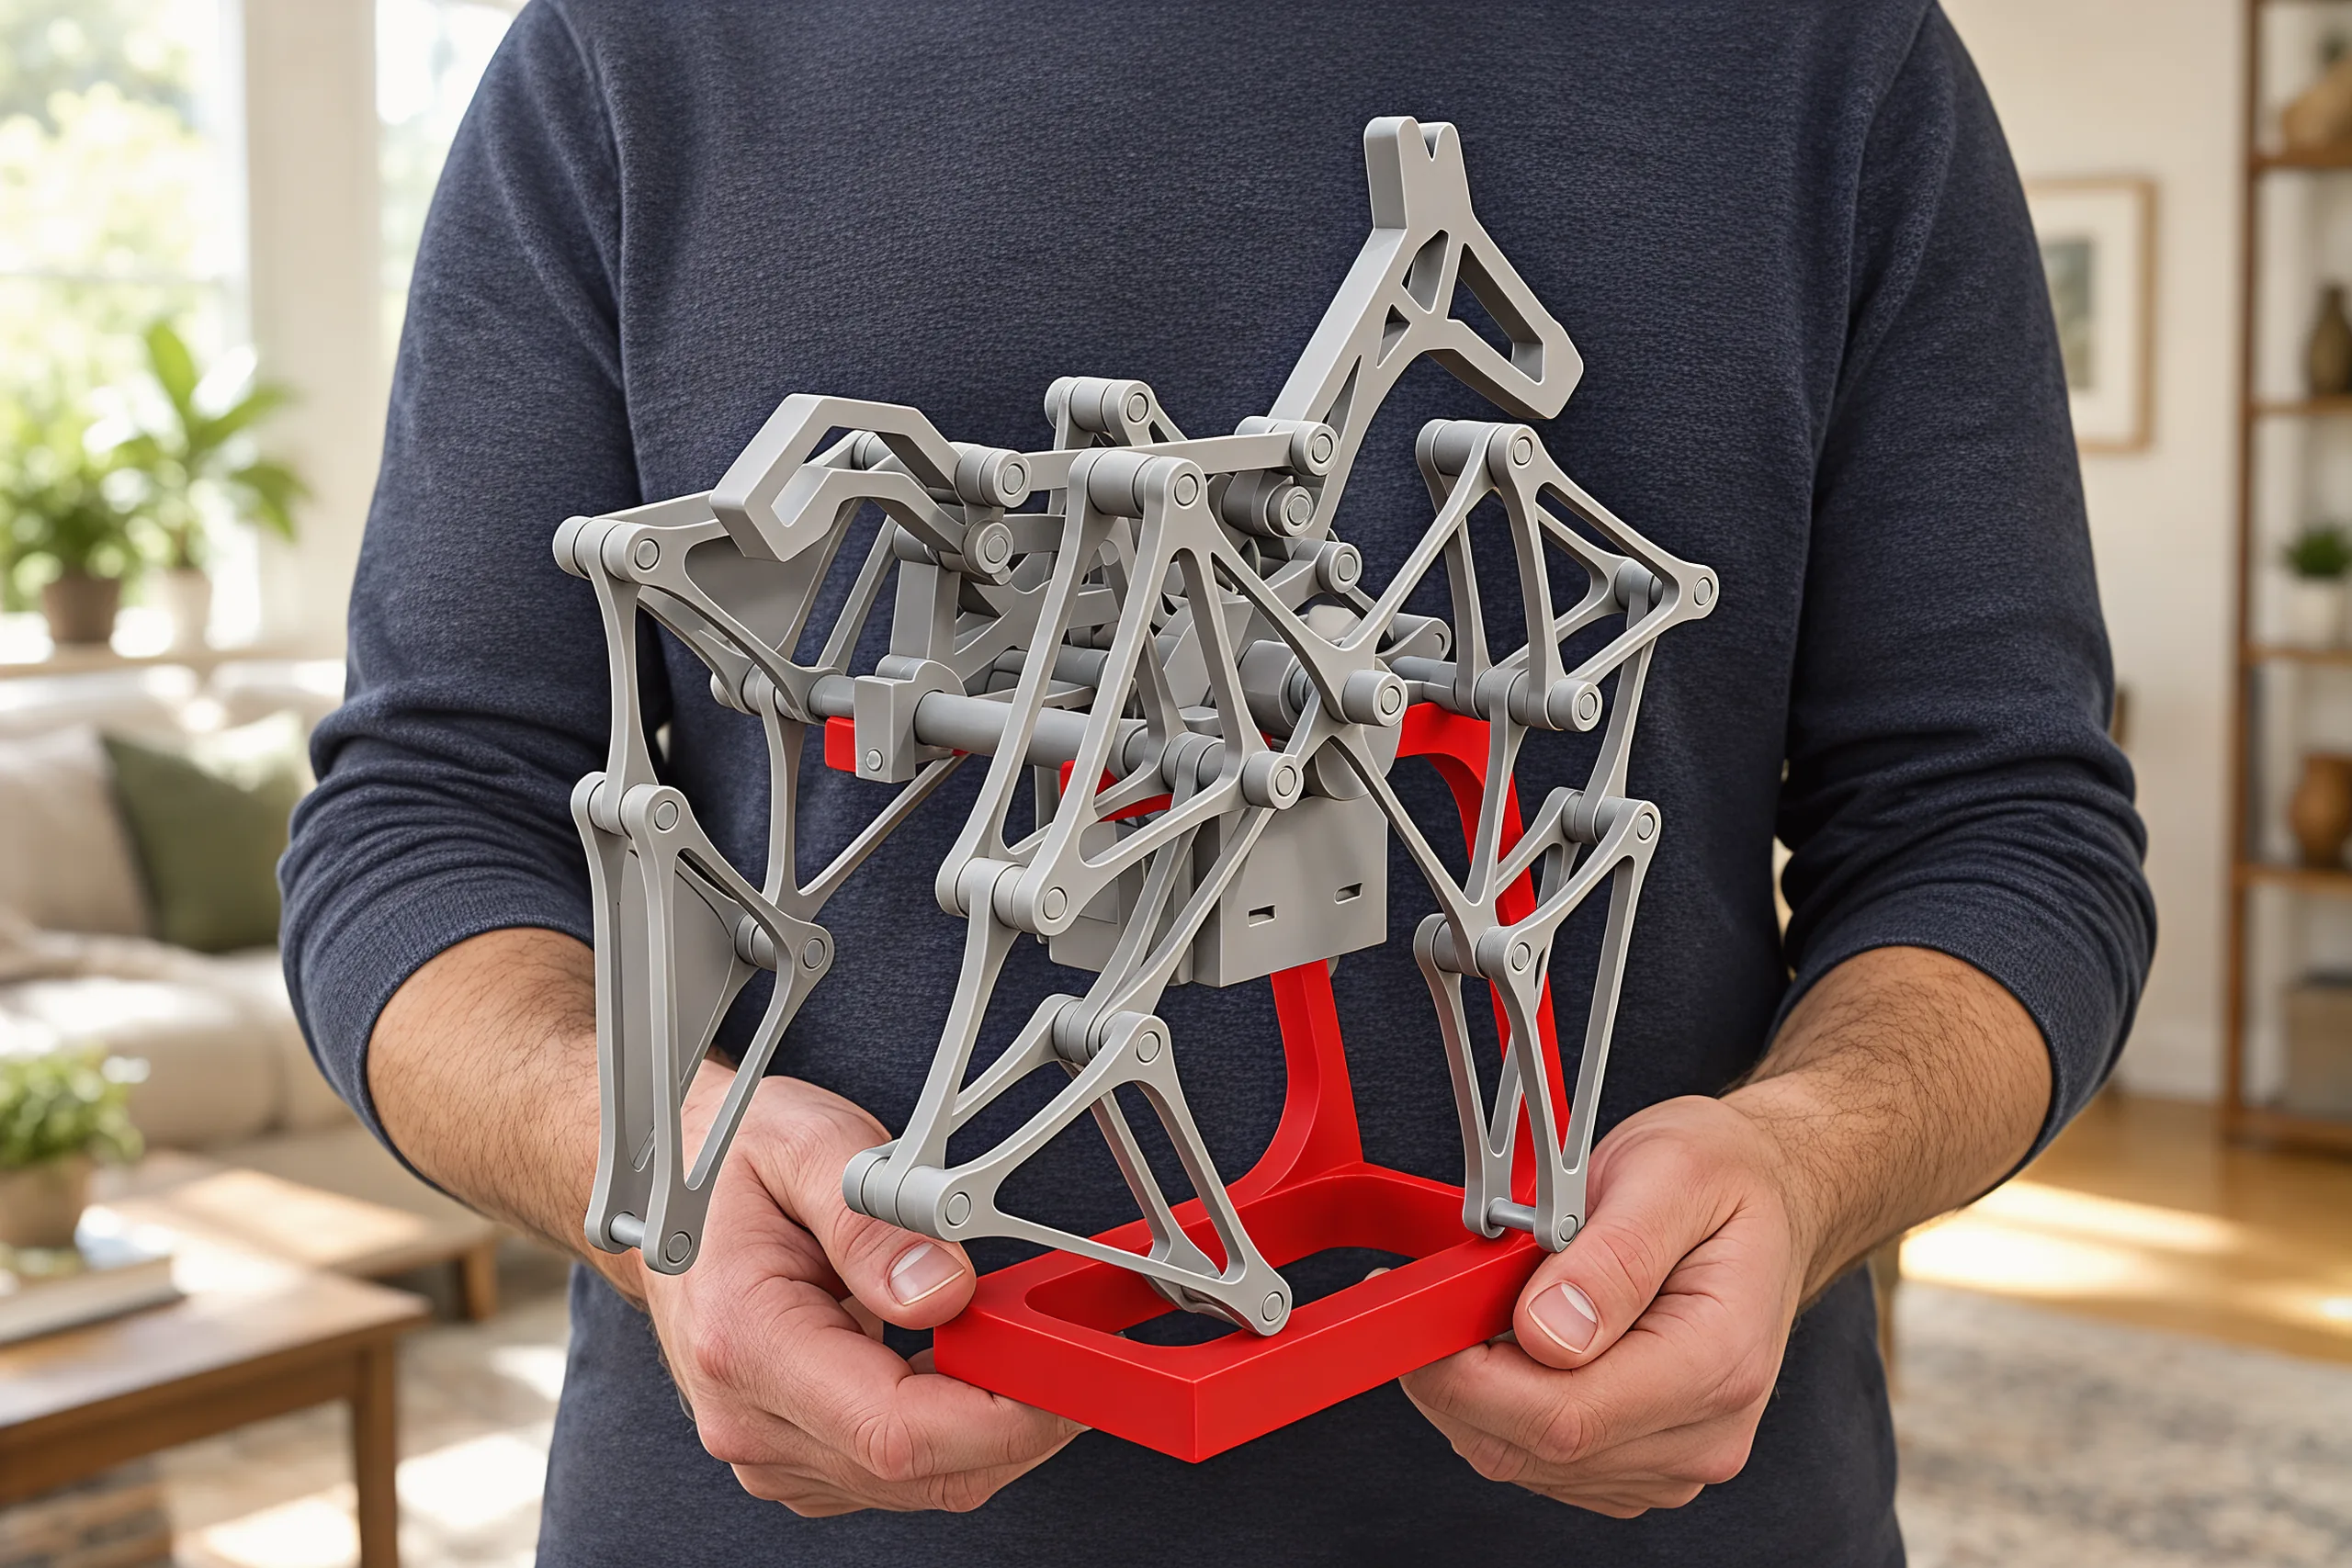
7.9 in tall and 5.4 oz. The whole horse is light grey PLA, an open frame of rods and pins you can see straight through, on a red stand that keeps it off the desk.
Eight moments in one turn of the crank, drawn from the leg geometry itself. The near side is solid and the far side faint. The sand line is the hoof's path, which shows the trick of a Jansen leg: a long, nearly flat stroke along the ground, then a high lift back.
Mechanical horse walker: a Jansen walker you can watch work.